Stories from the bench.
One week. A new robot. A demo in Paris.
Porting the LLM cobot from a Franka to a UR5e in three days, an 11-hour solo drive, and Jensen Huang signing the robot.
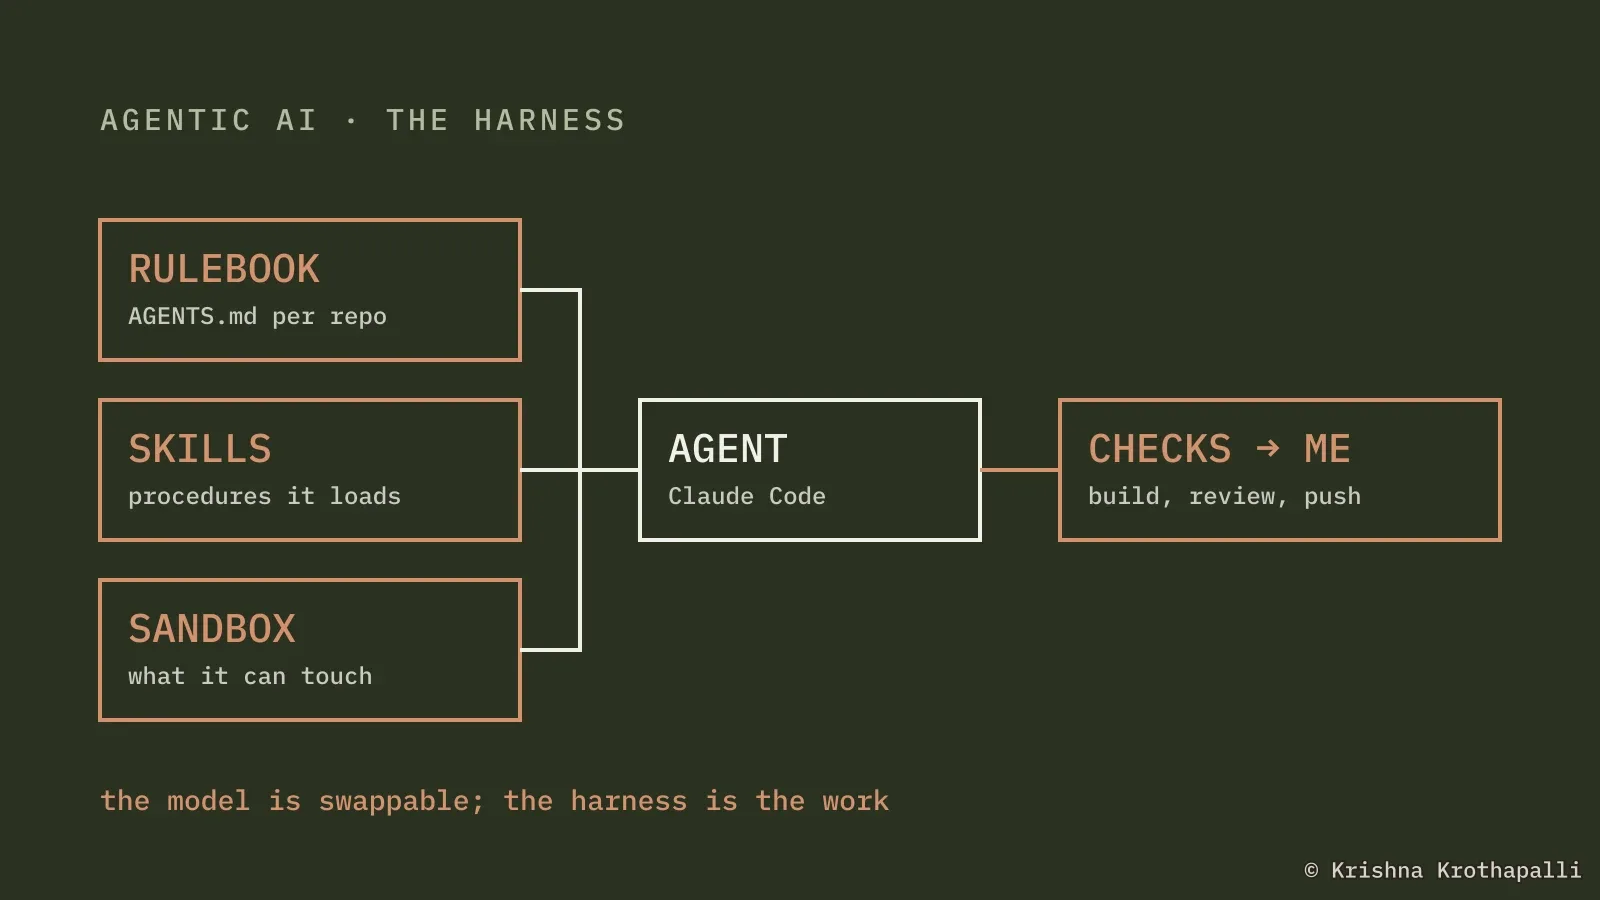
Working with coding agents: rules, skills and a sandbox
I use Claude Code for robot code, for research digging and for this site. The model is the easy part. What makes it reliable is the harness around it: a rulebook, skills, checks and a sandbox.
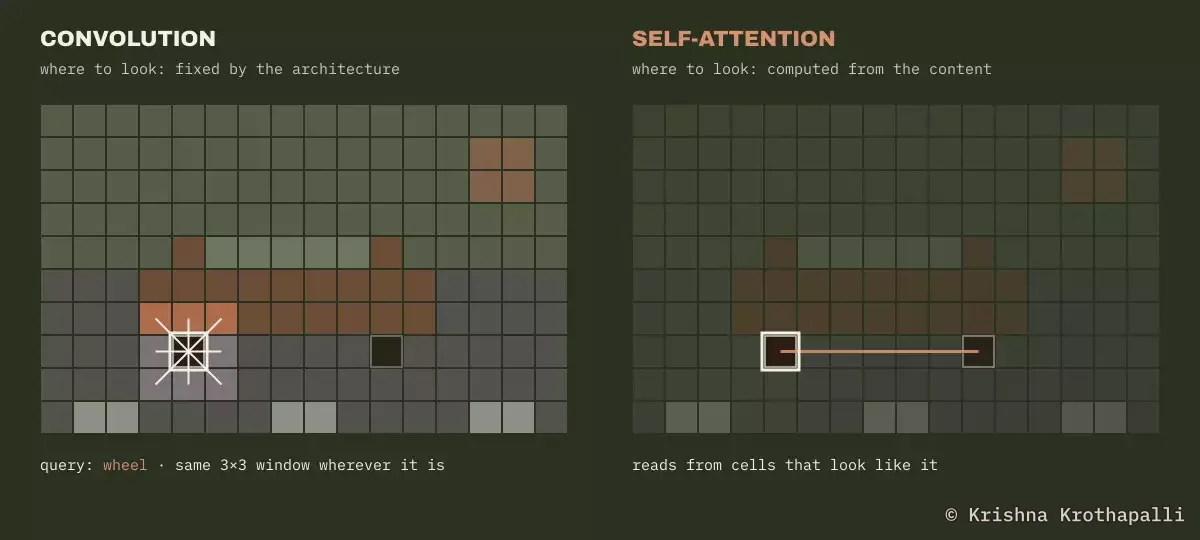
Who decides where to look: convolution vs attention
In a convolution, the routing is done by the architecture. In a transformer, it is done by self-attention. One idea that explains locality, data hunger, the n² cost, and why you can't cache a matcher.
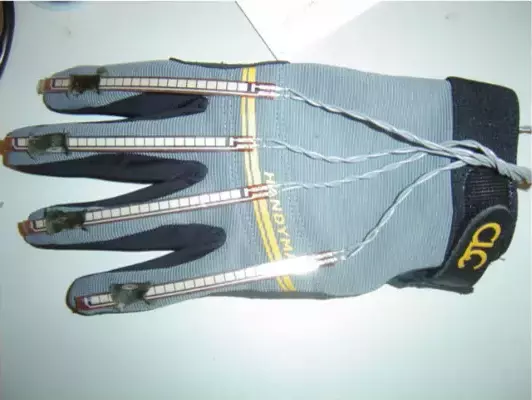
First steps to teleoperation
Flex sensors, a RealSense T265 and a 3D-printed bracket on a glove. Cheap, smooth, and not scalable.
Six years of perception for cars
ML engineer, then head of perception at ESR Labs, 2017–2022. Small, fast networks for the embedded hardware in cars, the path that got them there, and one study that didn't work.