Me, teleoperating a Unitree G1Whatever my arms do, it does
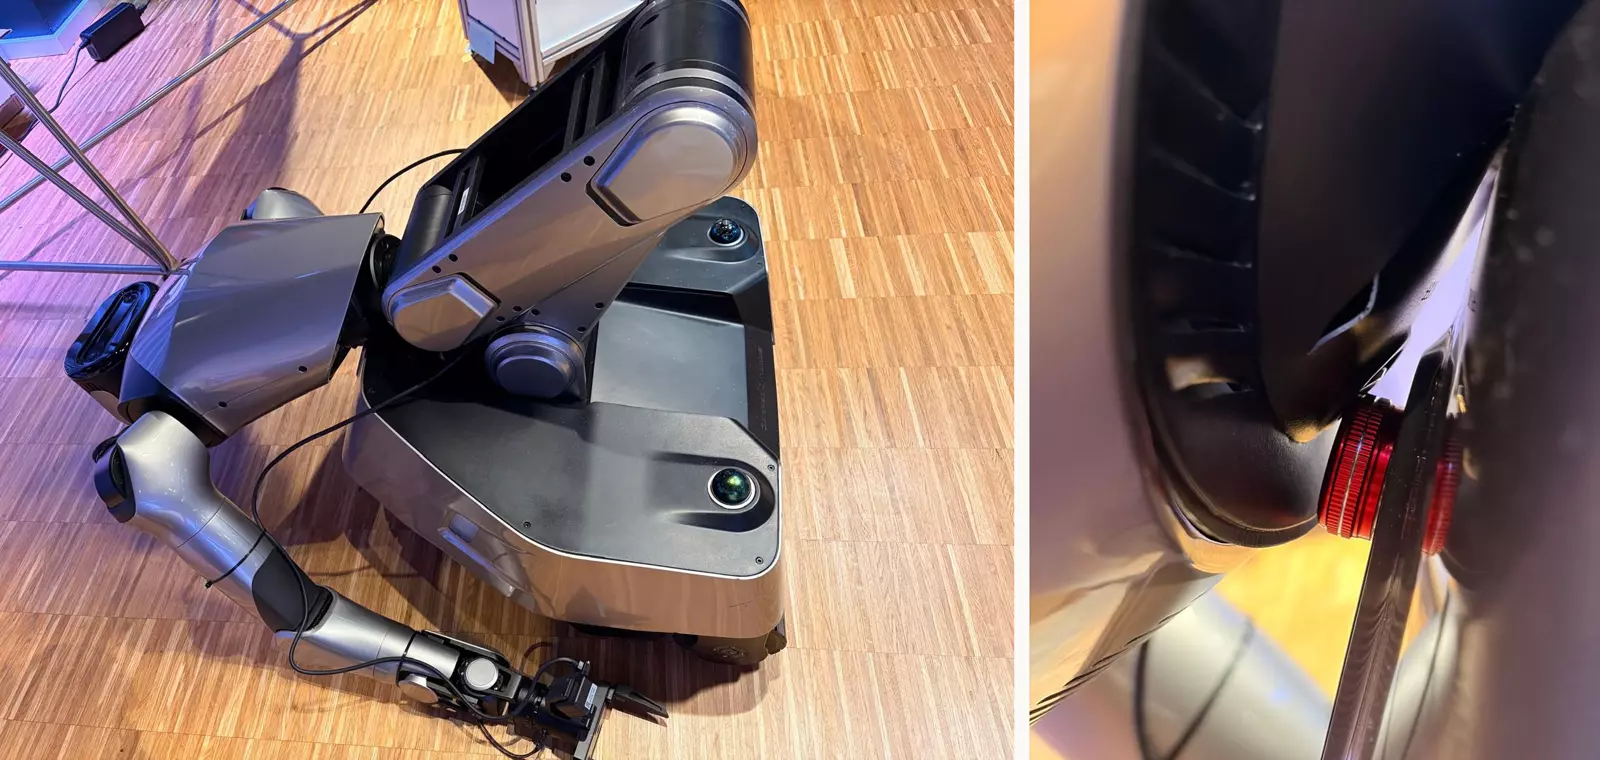
The R1 fell on itself and pressed its own E-stopPower button too. Self-shutdown, the hard way.
Showing off the Galaxea R1Shortly before it fell over
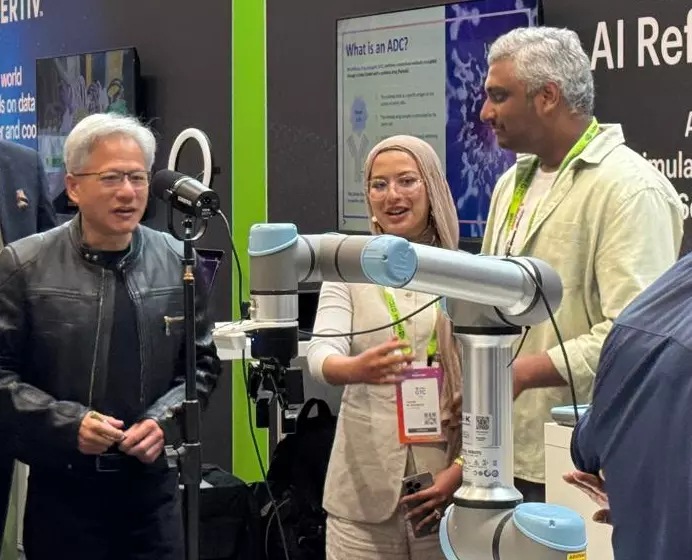
Jensen Huang at our booth. I'm on the right.GTC Paris 2025
Everything else
Paid in socksI took the AWS team's photo with Jensen. GTC ParisSegmentation plus stereo disparity, fitted into 3D boxesIn CARLA, where every car is a clean blue blob
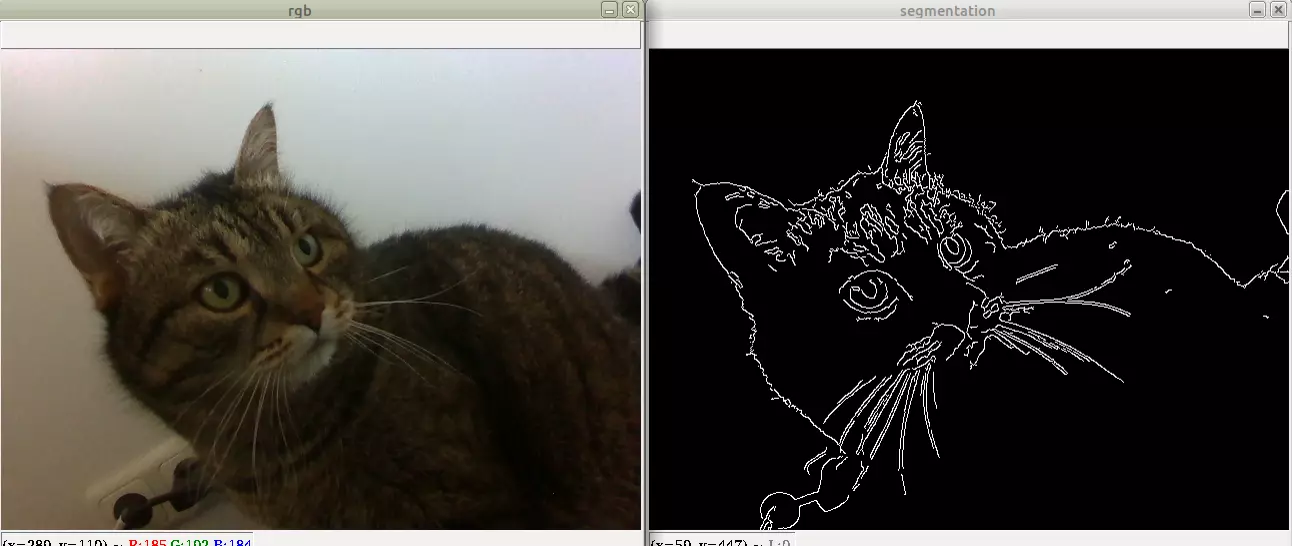
My cat, helping me tune edge detectionStrict reviewer. Rejected every threshold without whiskers.A UR arm planning around obstacles with cuMotionPlayed at 2× speedThe table-tennis bat had other plansA Franka grasp attempt. The bat slipped out.
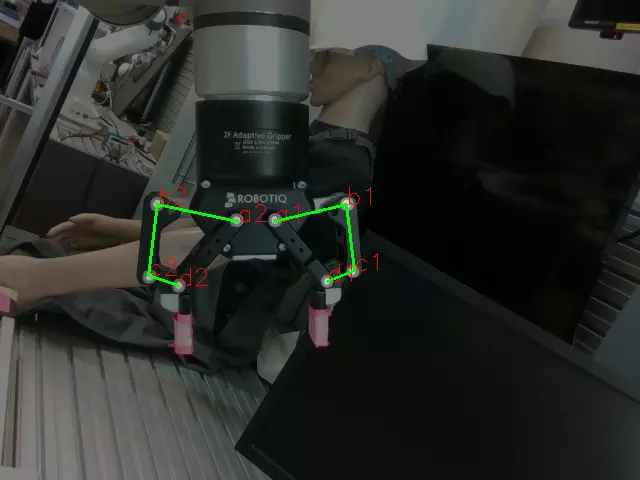
Four keypoints per finger on a Robotiq 2FWith a mannequin keeping watch
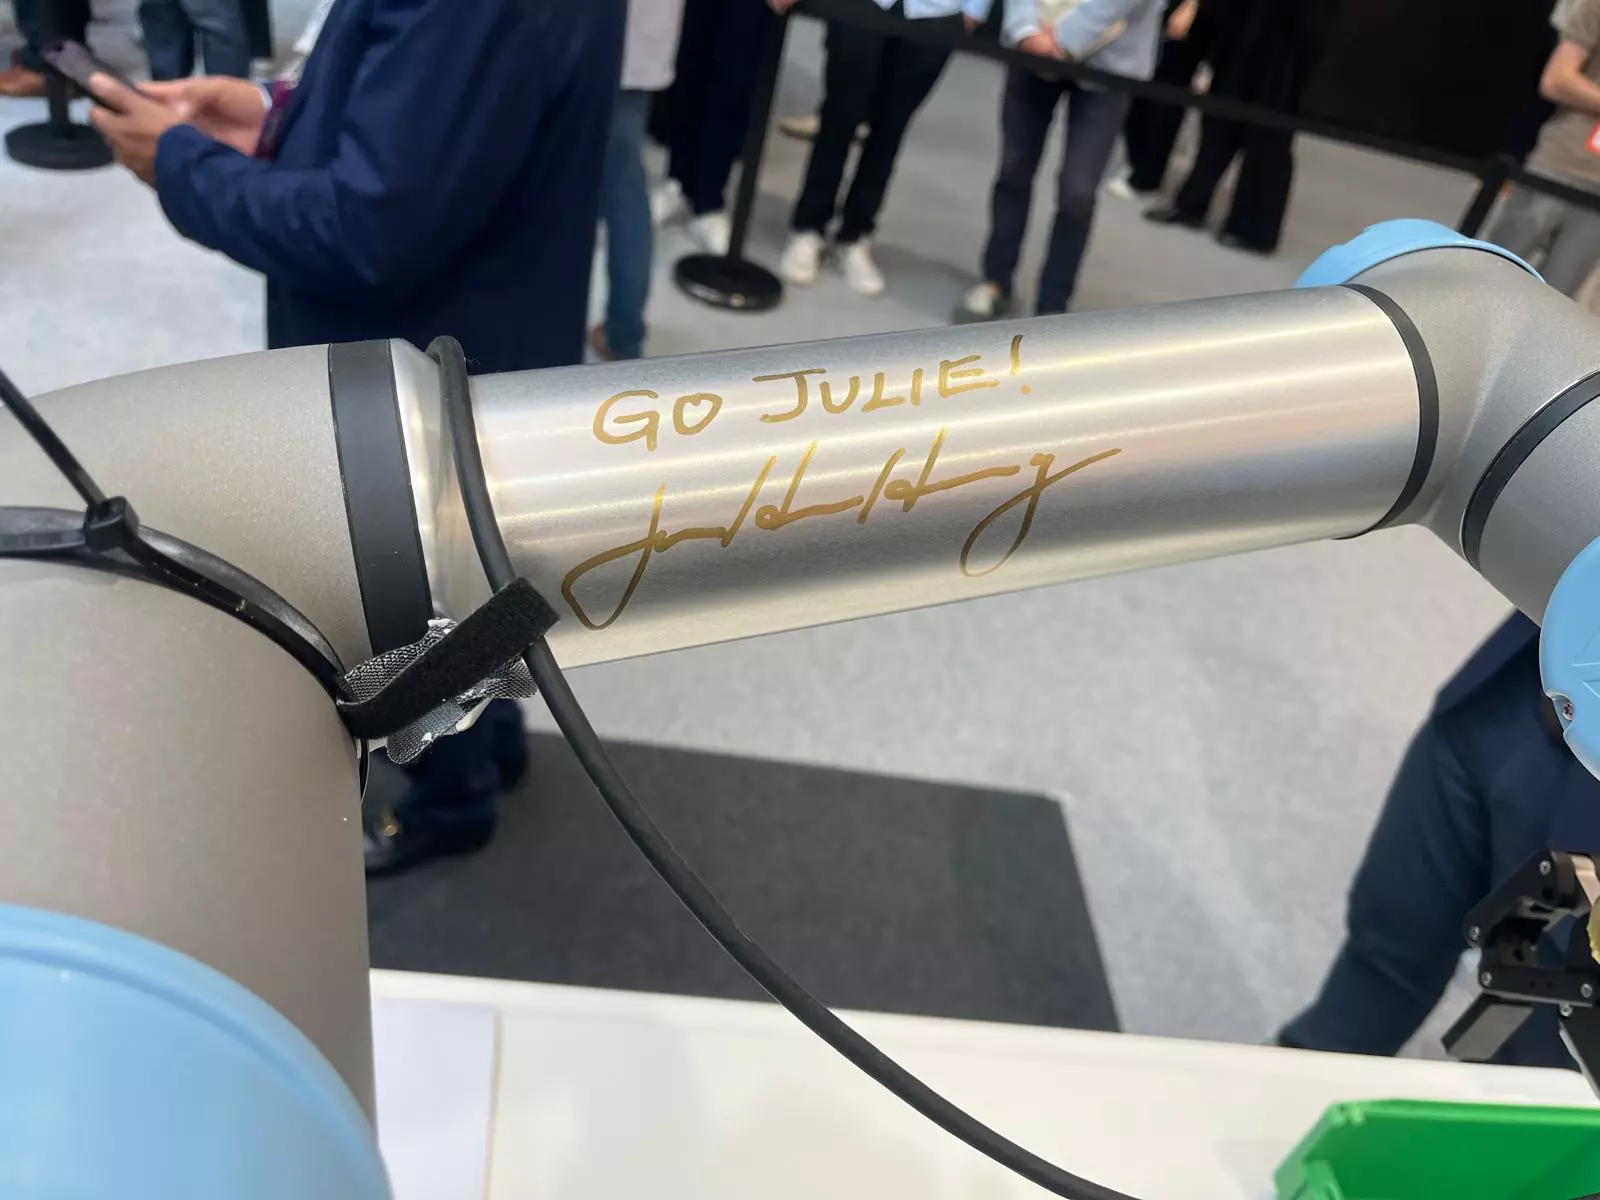
The robot, now with an autographSigned by Jensen Huang at GTC Paris
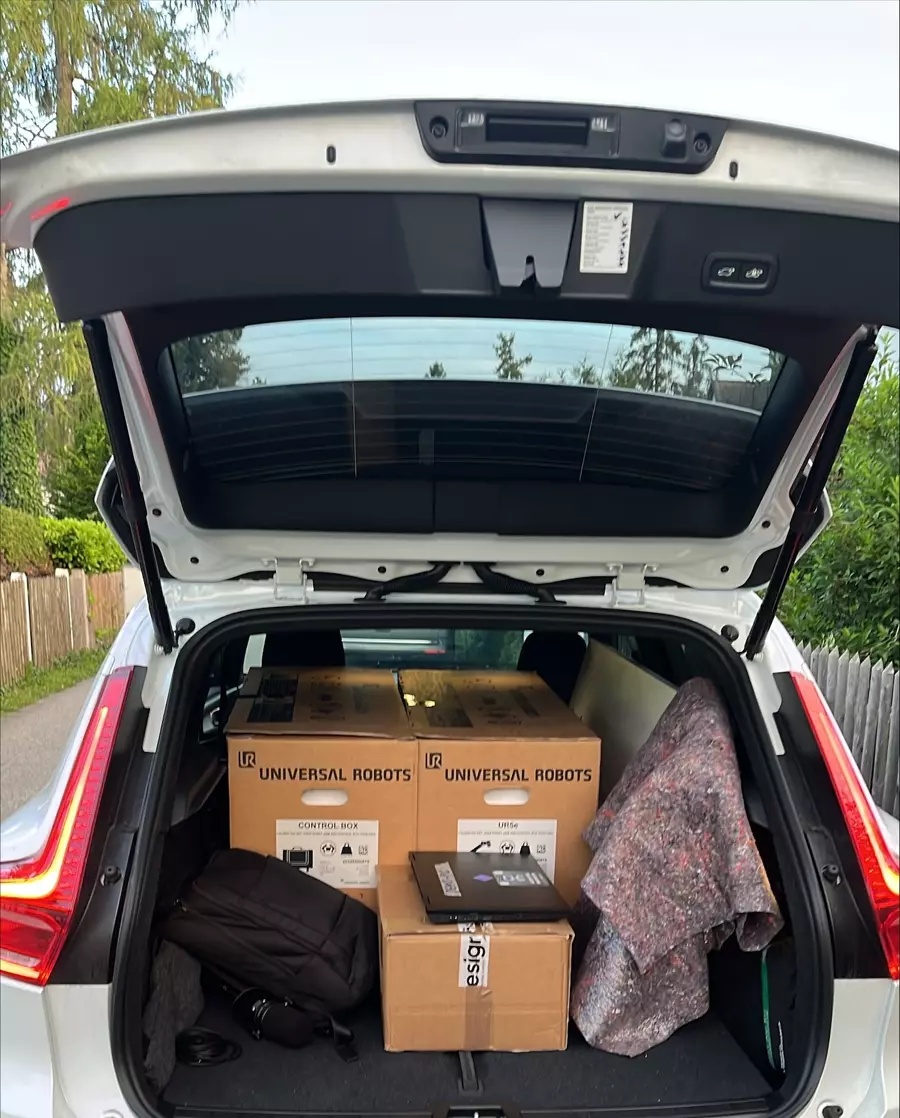
A UR5e in the boot, ready for ParisMunich → Paris, about 11 hours, GTC 2025
Things & stuff
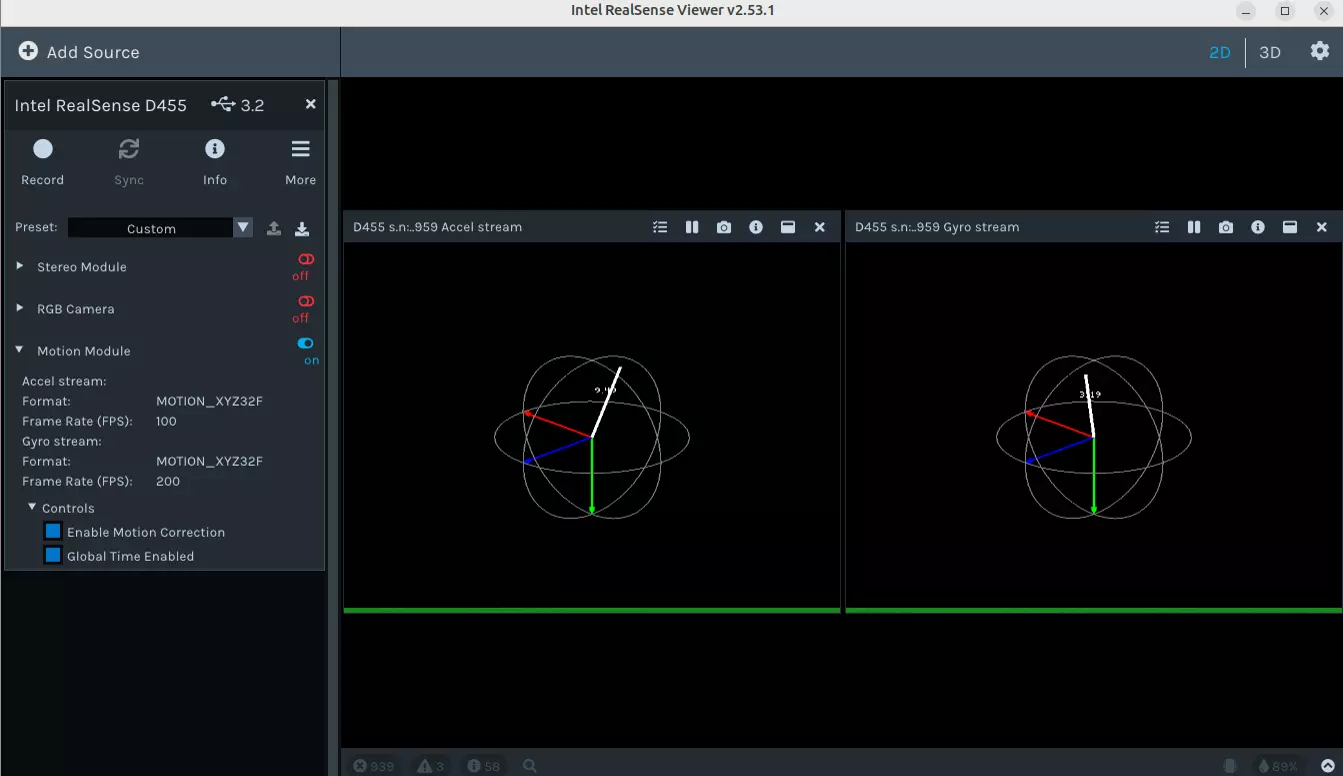
Checking the IMU on a RealSense D455Accel at 100 Hz, gyro at 200 Hz
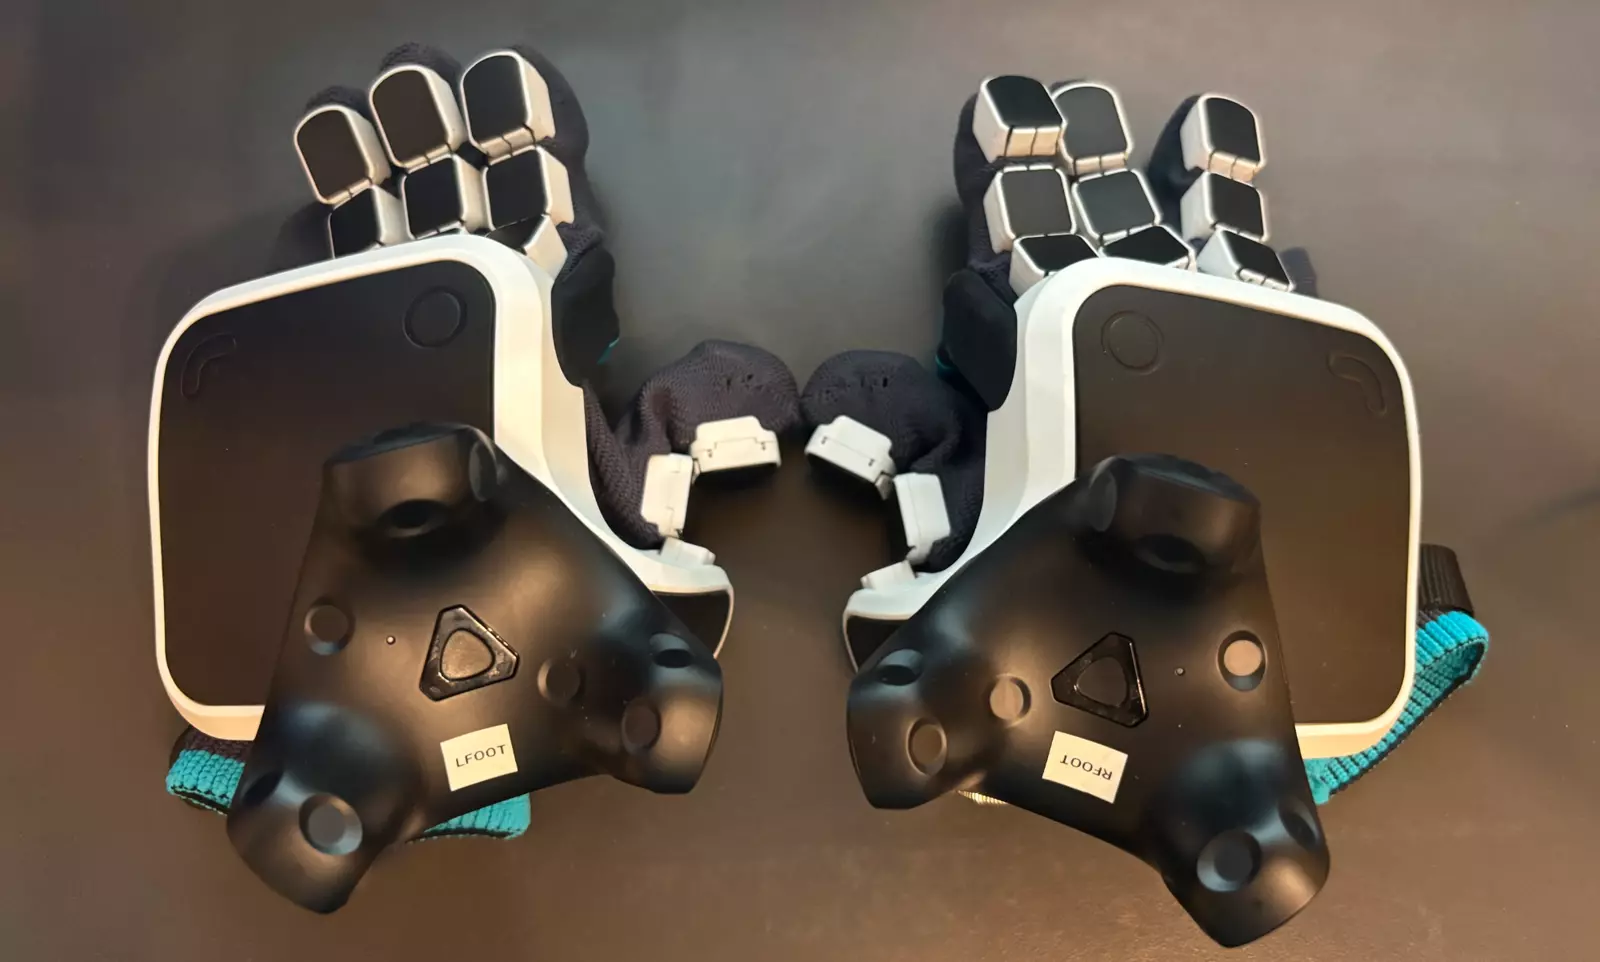
Nova2 gloves, trackers strapped onHeavy enough that you can't make a fistFlex sensors and a T265, stitched to a gloveFirst teleop glove, 2024Viper 300s following a Vive controllerQuick test before the humanoid
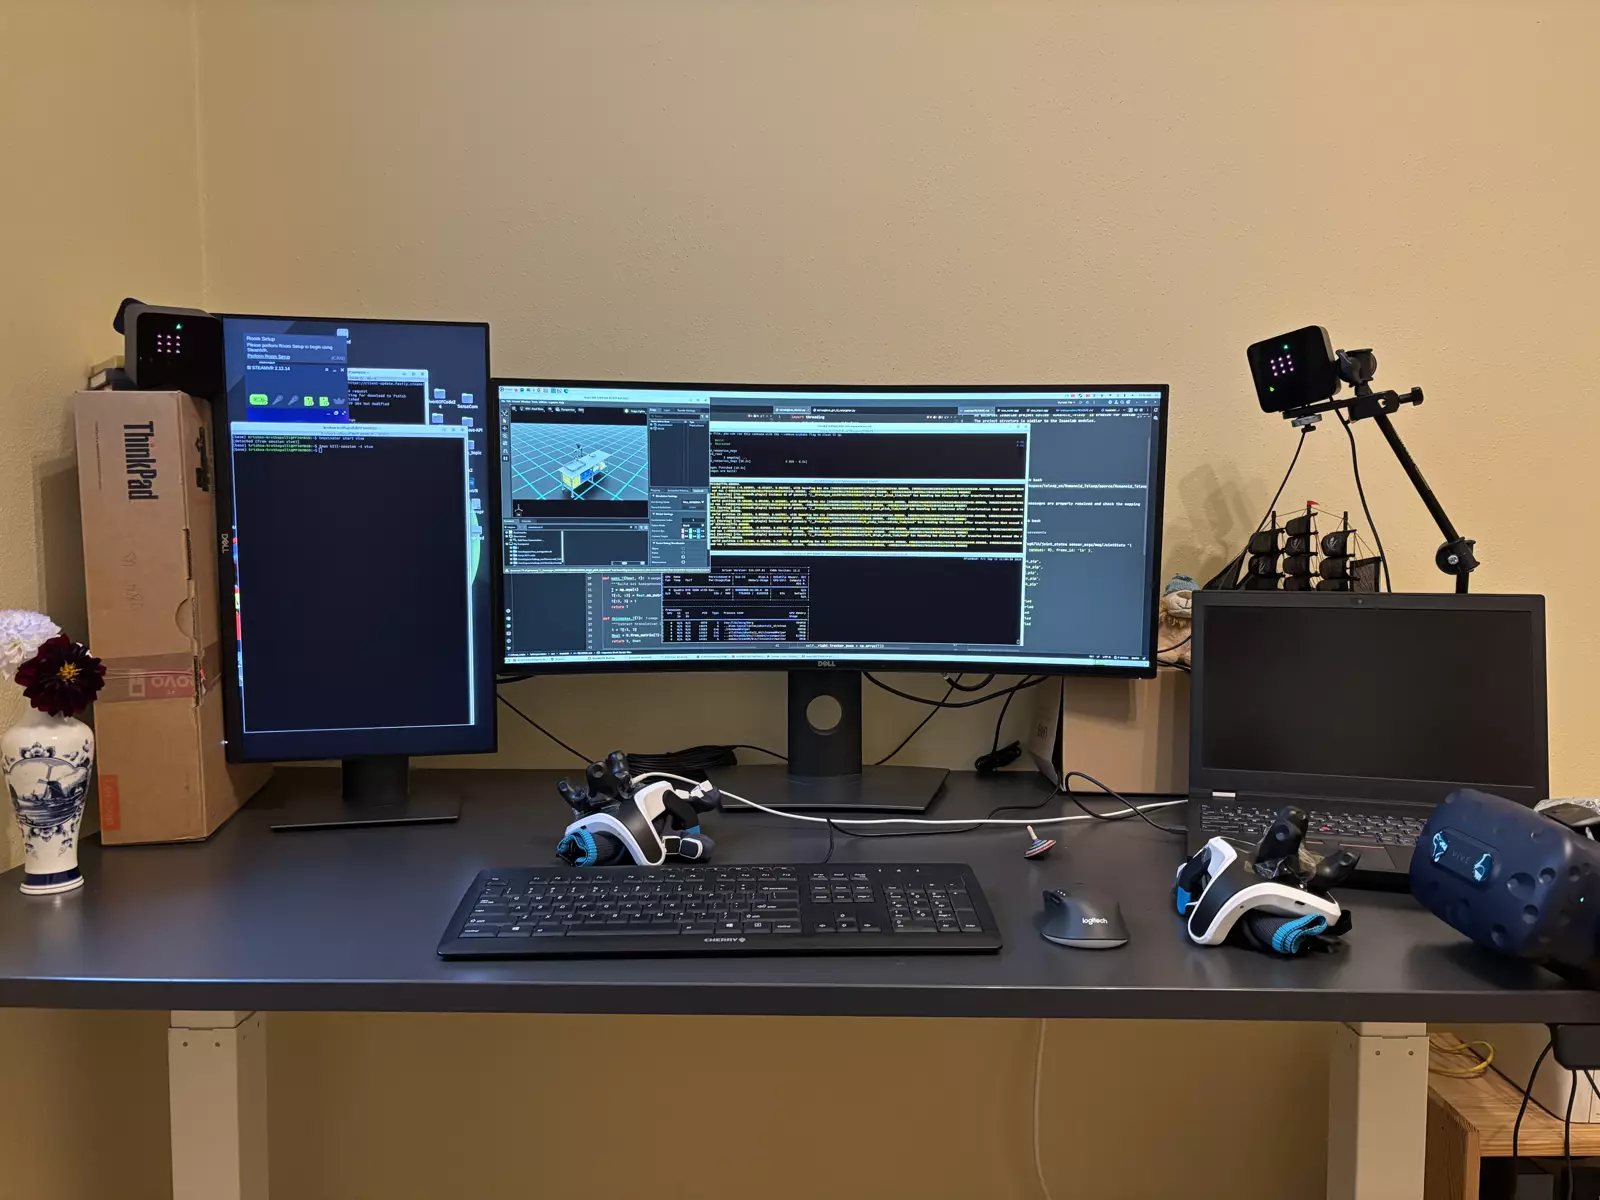
Base stations taking over the deskHumanoid teleop setup